Jiwon Park
Jiwon Park
Home
Projects
Publications
Experience
Posts
Talks
Contact
CV
Light
Dark
Automatic
Gaussian Splatting
2DGS-Planner preprint released on arXiv
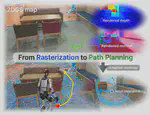
Our 2DGS-Planner preprint is now on arXiv, with an interactive project page showing rasterization-based planning and real-world humanoid navigation.
Oct 8, 2026
Jiwon Park
PDF
arXiv
Project Page
2DGS-Planner: Rasterization-based Path Planning in 2D Gaussian Splatting Map
2DGS-Planner queries rendered surfaces to build adaptive roadmaps and refine ground-robot paths directly in 2D Gaussian Splatting maps, with real-world humanoid deployment.
Jiwon Park
,
Dong-Uk Seo
,
Hyun Myung
PDF
Cite
DOI
arXiv
Project Page
[Seminar] Gaussian Splatting Meets Robotics : Research trend and topics from ICRA 2026
A seminar on research trends and topics at the intersection of Gaussian Splatting and robotics, based on ICRA 2026.
Jiwon Park
Jul 20, 2026
1 min read
Seminar
Cite
×