Jiwon Park
Jiwon Park
Home
Projects
Publications
Experience
Posts
Talks
Contact
CV
Light
Dark
Automatic
Robot Navigation
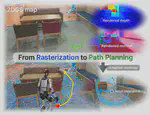
2DGS-Planner preprint released on arXiv
Our 2DGS-Planner preprint is now on arXiv, with an interactive project page showing rasterization-based planning and real-world humanoid navigation.
Oct 8, 2026
Jiwon Park
PDF
arXiv
Project Page
2DGS-Planner: Rasterization-based Path Planning in 2D Gaussian Splatting Map
2DGS-Planner queries rendered surfaces to build adaptive roadmaps and refine ground-robot paths directly in 2D Gaussian Splatting maps, with real-world humanoid deployment.
Jiwon Park
,
Dong-Uk Seo
,
Hyun Myung
PDF
Cite
DOI
arXiv
Project Page
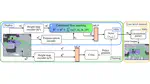
DreamFlow: Local Navigation Beyond Observation via Conditional Flow Matching in the Latent Space
DreamFlow is a deep RL framework that uses conditional flow matching to extend a robot’s perceptual range beyond its sensor FOV, enabling proactive navigation around unseen obstacles in cluttered environments.
Jiwon Park
,
Dongkyu Lee
,
I Made Aswin Nahrendra
,
Jaeyoung Lim
,
Hyun Myung
PDF
DOI
arXiv
Project Page
Cite
×