2DGS-Planner preprint released on arXiv
Date
Oct 8, 2026
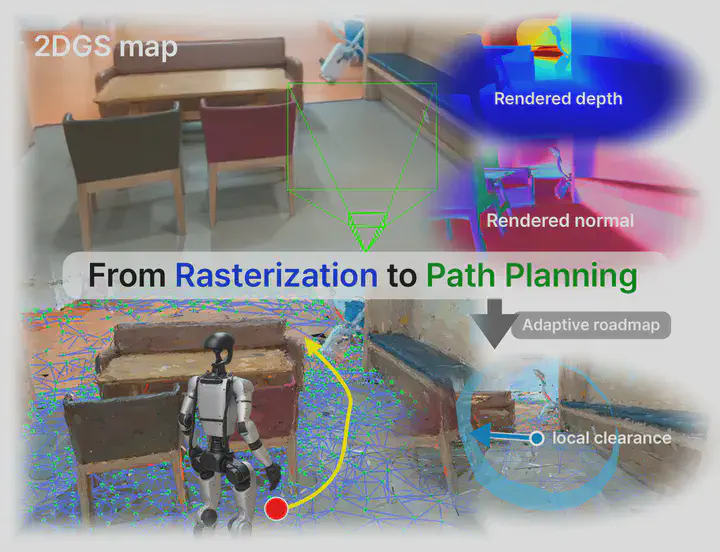
Our preprint 2DGS-Planner: Rasterization-based Path Planning in 2D Gaussian Splatting Map, by Jiwon Park, Dong-Uk Seo, and Hyun Myung, is now available on arXiv.
2DGS-Planner reads geometry through rasterization to build adaptive roadmaps and refine paths directly in 2D Gaussian Splatting maps. The project page includes interactive comparisons, planning results, and a real-world humanoid demonstration.

Jiwon Park
My research interests include perception for robust off-road mobile robot